Measures
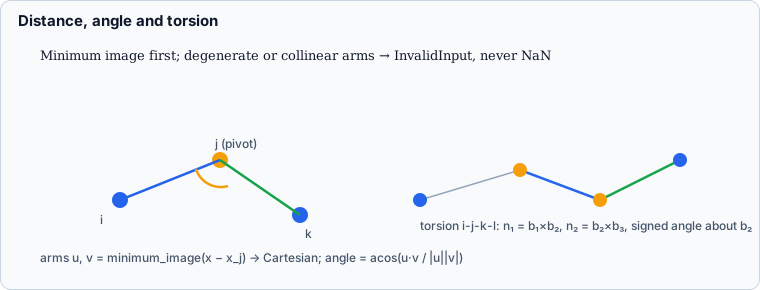
Distance, angle and torsion use the minimum image of the P1 cell, so a measurement across a boundary equals the same local geometry inside the cell.
For a pivot j, the arms are minimum_image(x_i - x_j) and minimum_image(x_k - x_j), converted to Cartesian. The angle is acos(u·v / |u||v|). The torsion uses the two plane normals n1 = b1 × b2 and n2 = b2 × b3 and the signed angle around b2.
Degenerate arms, collinear segments and zero normals return Error::InvalidInput rather than a silent NaN. Centroids and interplanar angles are plain Cartesian operations.